Project lead · VITALS search and rescue
Multi-drone search-and-rescue system
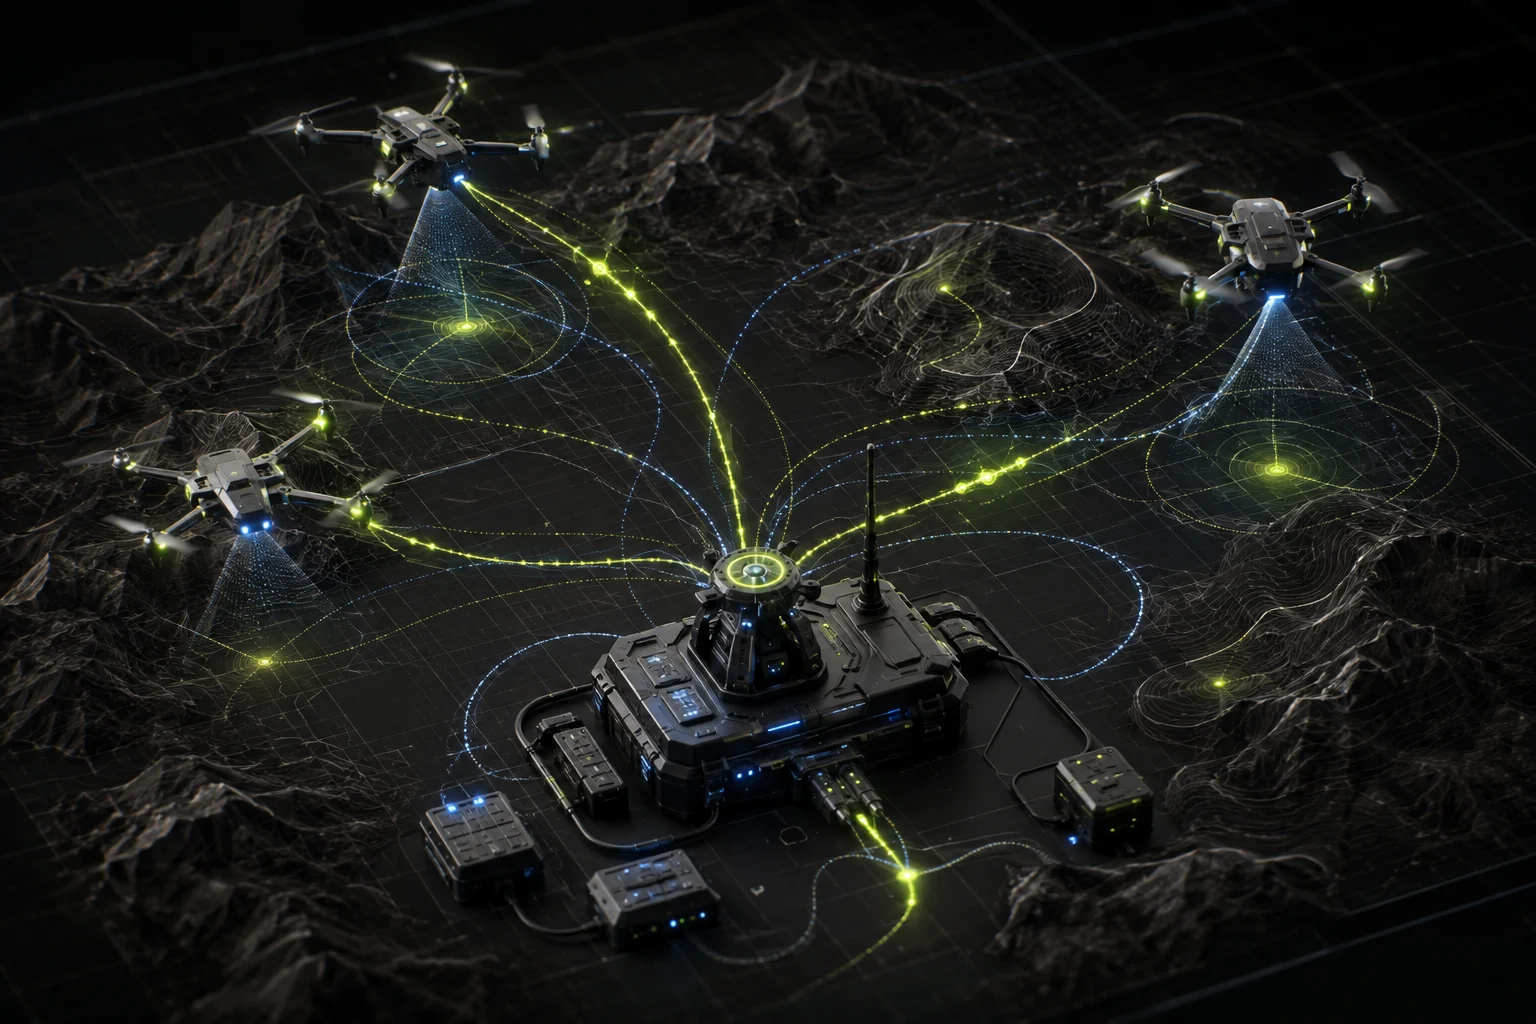
Led a six-person cross-functional team building a distributed search-and-rescue system across UAVs, ground-control software, telemetry radios, flight controllers, and an NVIDIA Jetson Nano.
- Built Python MAVLink UDP/TCP tooling between aircraft, ground control, and edge compute on Ubuntu Linux.
- Standardized RFD900+ and RFD900x telemetry firmware and cabling for Pixhawk controllers.
- Validated authorization, command integrity, and end-to-end behavior through hardware-in-the-loop testing.